Weiler Moosbach
Moosbach, K 7 · scenario moosbach
2026-10-04 session 4
What the judge counted (44)
| 0.5 s | dithering | plan target speed oscillated by 23 km/h or more, two cycles in 0.4 s |
| 2.9 s | dithering | plan target speed oscillated by 7 km/h or more, two cycles in 2.2 s |
| 3.6 s | dithering | plan target speed oscillated by 15 km/h or more, two cycles in 0.6 s |
| 4.4 s | dithering | plan target speed oscillated by 10 km/h or more, two cycles in 0.9 s |
| 5.3 s | unjustified_stop | 0 km/h for 1.0 s without a justifying cause |
| 8.6 s | dithering | plan target speed oscillated by 20 km/h or more, two cycles in 3.5 s |
| 9.9 s | dithering | plan target speed oscillated by 12 km/h or more, two cycles in 2.1 s |
| 12.4 s | dithering | plan target speed oscillated by 7 km/h or more, two cycles in 2.3 s |
| 15.7 s | dithering | behaviour flipped car_follow <-> stop 3 times in 0.1 s |
| 16.7 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 0.7 s |
| 16.8 s | dithering | plan target speed oscillated by 10 km/h or more, two cycles in 4.4 s |
| 17.2 s | dithering | plan target speed oscillated by 14 km/h or more, two cycles in 0.4 s |
| 19.6 s | dithering | plan target speed oscillated by 10 km/h or more, two cycles in 2.4 s |
| 20.0 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 0.3 s |
| 20.8 s | dithering | plan target speed oscillated by 10 km/h or more, two cycles in 0.9 s |
| 20.9 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 0.7 s |
| 24.9 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 1.6 s |
| 24.9 s | dithering | plan target speed oscillated by 19 km/h or more, two cycles in 4.4 s |
| 25.1 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 0.1 s |
| 25.9 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 0.6 s |
| 26.3 s | dithering | plan target speed oscillated by 16 km/h or more, two cycles in 1.4 s |
| 26.5 s | unjustified_stop | 0 km/h for 1.1 s without a justifying cause |
| 28.2 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 1.4 s |
| 29.6 s | dithering | plan target speed oscillated by 14 km/h or more, two cycles in 3.1 s |
| 30.4 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 1.7 s |
| 32.4 s | dithering | plan target speed oscillated by 14 km/h or more, two cycles in 2.2 s |
| 34.1 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 0.9 s |
| 35.4 s | dithering | plan target speed oscillated by 12 km/h or more, two cycles in 3.6 s |
| 36.0 s | unjustified_stop | 0 km/h for 1.1 s without a justifying cause |
| 38.0 s | phantom_brake | decelerated at 2.4 m/s² at t = 34.0 s without a cause in the next 4 s |
| 38.0 s | dithering | plan target speed oscillated by 12 km/h or more, two cycles in 2.6 s |
| 40.1 s | dithering | plan target speed oscillated by 10 km/h or more, two cycles in 1.8 s |
| 40.2 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 4.9 s |
| 43.0 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 1.1 s |
| 43.1 s | unjustified_stop | 0 km/h for 1.1 s without a justifying cause |
| 43.5 s | dithering | plan target speed oscillated by 12 km/h or more, two cycles in 3.8 s |
| 46.0 s | phantom_brake | speed dropped from 11 to 1 km/h at t = 42.0 s without a cause in the next 4 s |
| 71.2 s | dithering | plan target speed oscillated by 16 km/h or more, two cycles in 5.9 s |
| 73.5 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 1.2 s |
| 73.8 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 0.3 s |
| 74.8 s | dithering | plan target speed oscillated by 6 km/h or more, two cycles in 3.2 s |
| 76.2 s | dithering | plan target speed oscillated by 21 km/h or more, two cycles in 1.5 s |
| 76.8 s | unjustified_stop | 0 km/h for 1.0 s without a justifying cause |
| 79.2 s | dithering | plan target speed oscillated by 18 km/h or more, two cycles in 3.0 s |
passed with faults newest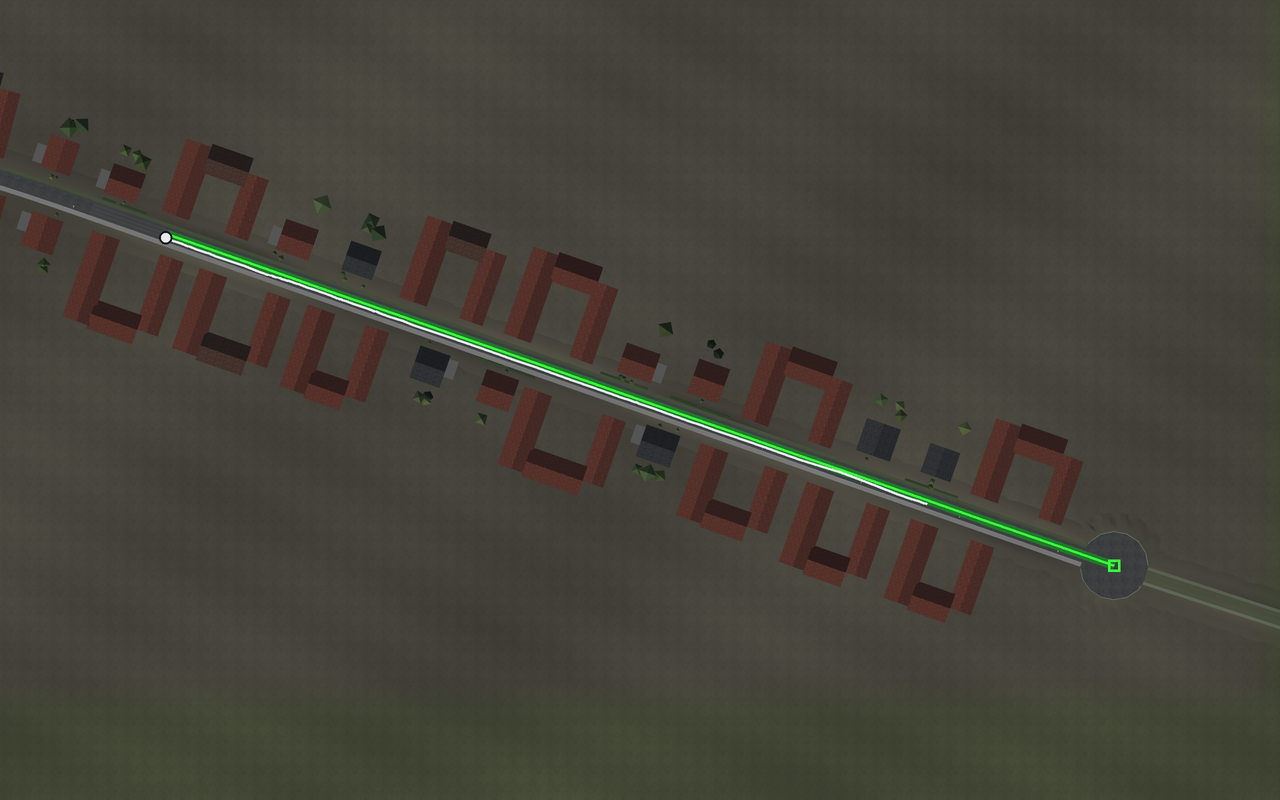
The user's words about the clip of 2026-10-04 session 4, written 2026-10-05“better, but stopped a lot and didnt pass smoothly”
The lead's reading, not the user's and not the judge's
263 m in 80 s on the unmarked village road: four stops without a cause.
What changed since the version before: first version
route asked fordriven× collision or off the road
Run
- version
- 2026-10-04 session 4
- scenario
- view_moosbach
- ended
- time limit
- time
- 80.0 s
- distance
- 263 m
- mean speed
- 11.8 km/h
- stops
- 4
- code
- master c197752
- perception
- learned, front + tele
- seed
- 3