Out of Hagendorf
Hagendorf · scenario hagendorf_route_r2
2026-10-04 session 4
What the judge counted (47)
| 5.3 s | dithering | plan target speed oscillated by 6 km/h or more, two cycles in 4.8 s |
| 8.4 s | dithering | plan target speed oscillated by 6 km/h or more, two cycles in 3.5 s |
| 15.3 s | unjustified_stop | 0 km/h for 1.1 s without a justifying cause |
| 16.1 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 1.2 s |
| 16.6 s | phantom_brake | decelerated at 2.0 m/s² at t = 12.6 s without a cause in the next 4 s |
| 17.9 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 1.1 s |
| 19.0 s | dithering | plan target speed oscillated by 7 km/h or more, two cycles in 4.1 s |
| 19.9 s | dithering | plan target speed oscillated by 7 km/h or more, two cycles in 0.9 s |
| 20.3 s | dithering | plan target speed oscillated by 8 km/h or more, two cycles in 0.4 s |
| 22.2 s | dithering | plan target speed oscillated by 8 km/h or more, two cycles in 0.2 s |
| 23.1 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 4.8 s |
| 27.1 s | dithering | plan target speed oscillated by 14 km/h or more, two cycles in 6.6 s |
| 33.6 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 0.3 s |
| 34.8 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 0.4 s |
| 35.3 s | unjustified_stop | 0 km/h for 1.0 s without a justifying cause |
| 38.9 s | unsafe_overtake | oncoming tractor tractor_002 had to brake at 5.0 m/s² 83 m ahead of the ego, which was passing pedestrian_001 |
| 41.0 s | dithering | plan target speed oscillated by 7 km/h or more, two cycles in 3.5 s |
| 42.1 s | dithering | plan target speed oscillated by 15 km/h or more, two cycles in 3.1 s |
| 42.9 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 8.0 s |
| 44.1 s | dithering | plan target speed oscillated by 24 km/h or more, two cycles in 2.4 s |
| 47.8 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 3.9 s |
| 50.1 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 2.1 s |
| 50.4 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 0.1 s |
| 50.4 s | dithering | plan target speed oscillated by 26 km/h or more, two cycles in 6.6 s |
| 51.3 s | unjustified_stop | 0 km/h for 1.0 s without a justifying cause |
| 51.6 s | dithering | plan target speed oscillated by 28 km/h or more, two cycles in 1.2 s |
| 52.6 s | dithering | behaviour flipped lane_follow <-> car_follow 3 times in 1.9 s |
| 54.4 s | phantom_brake | speed dropped from 10 to 0 km/h at t = 50.4 s without a cause in the next 4 s |
| 54.5 s | dithering | behaviour flipped car_follow <-> lane_follow 3 times in 1.1 s |
| 58.2 s | dithering | plan target speed oscillated by 7 km/h or more, two cycles in 5.2 s |
| 63.4 s | dithering | behaviour flipped turn <-> yield 3 times in 2.4 s |
| 64.6 s | dithering | plan target speed oscillated by 9 km/h or more, two cycles in 6.3 s |
| 72.1 s | dithering | plan target speed oscillated by 12 km/h or more, two cycles in 1.6 s |
| 74.0 s | comfort_jerk | jerk -2.1 m/s³ (comfort limit 2) at 16 km/h outside an emergency |
| 75.7 s | wrong_side | car centre on the left half of E_angerweg_01 for 1.1 s with nothing being passed |
| 75.7 s | comfort_jerk | jerk +2.3 m/s³ (comfort limit 2) at 14 km/h outside an emergency |
| 76.2 s | off_road | 2 wheels off the drivable surface |
| 83.4 s | comfort_jerk | jerk -5.4 m/s³ (comfort limit 2) at 33 km/h outside an emergency |
| 83.7 s | comfort_brake | deceleration 5.6 m/s² (comfort limit 3) outside an emergency |
| 84.5 s | comfort_jerk | jerk +2.8 m/s³ (comfort limit 2) at 16 km/h outside an emergency |
| 85.7 s | wrong_side | car centre on the left half of E_angerweg_01 for 11.1 s with nothing being passed |
| 88.0 s | dithering | plan target speed oscillated by 8 km/h or more, two cycles in 6.4 s |
| 92.0 s | missing_indicator | no right indicator for overtaking (back in) on E_angerweg_01 |
| 92.0 s | lane_departure | car centre crossed the dividing line of E_angerweg_01 to the right without a right indicator |
| 92.2 s | collision | tractor tractor_003 |
| 94.7 s | dithering | plan target speed oscillated by 17 km/h or more, two cycles in 6.5 s |
| 99.5 s | dithering | behaviour flipped turn <-> stop 3 times in 0.1 s |
failed newest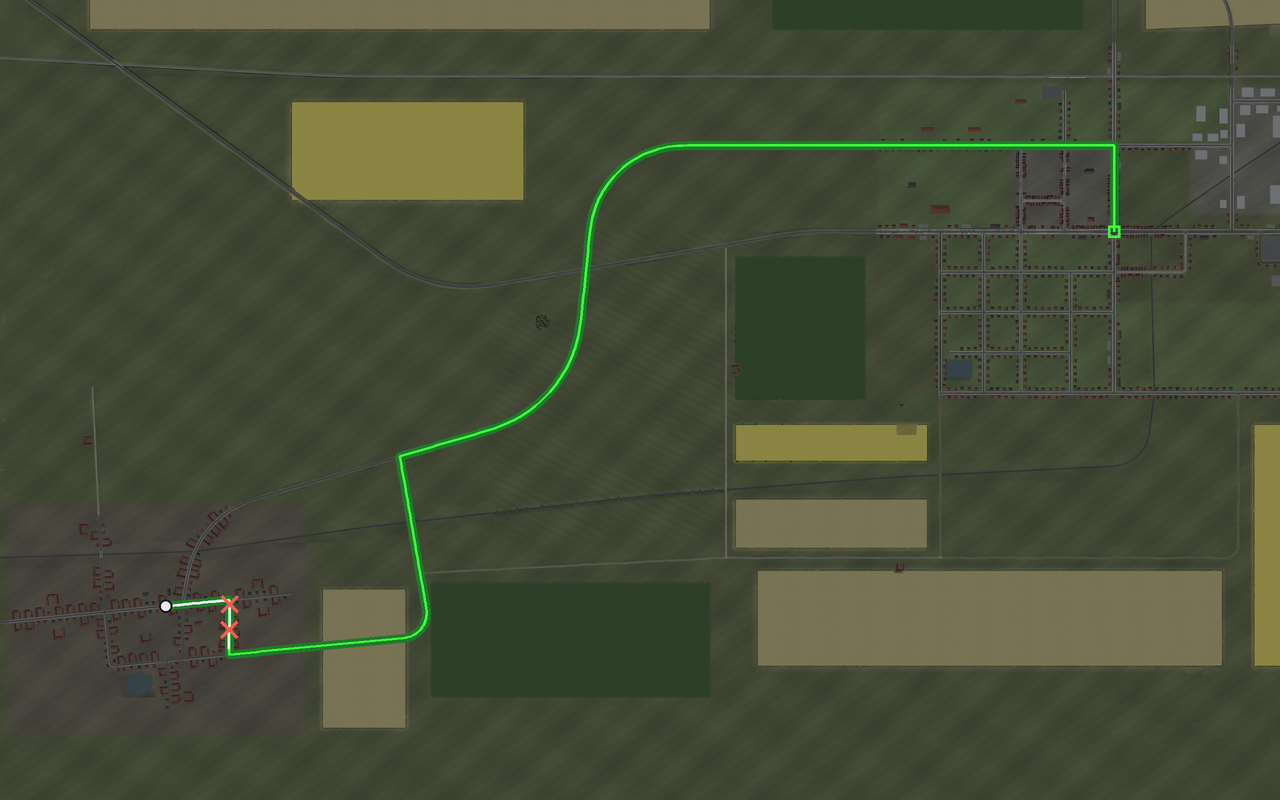
The user's words about the clip of 2026-10-04 session 4, written 2026-10-05“jerked a bit at 0:05, then came to a complete stop at 0:14 for no reason, then didnt dare to drive past the pedestrian at 1:05, it stopped way to early it should drive to the start of the t crossing, after tuning at that crossing it went on the wrong side of the road and stayed there”
The lead's reading, not the user's and not the judge's
Leaves the road in the village, one collision, wrong side twice.
What changed since the version before: first version
route asked fordriven× collision or off the road
Run
- version
- 2026-10-04 session 4
- scenario
- R2
- ended
- time limit
- time
- 100.0 s
- distance
- 362 m
- mean speed
- 13.0 km/h
- stops
- 4
- code
- master c197752
- perception
- learned, front + tele
- seed
- 3