Level crossing
K 7 Ost · scenario bahnuebergang_k7
2026-10-04 session 4
What the judge counted (11)
| 1.5 s | blind_pass | blind pass of cyclist_005 at walking pace (5 km/h): 159 m of true sight < 216 m needed at E_k7_ost_02 s 756 |
| 1.5 s | unsafe_overtake | oncoming car car_001 had to brake at 6.9 m/s² 121 m ahead of the ego, which was passing cyclist_005 |
| 2.3 s | lane_departure | car centre crossed the dividing line of E_k7_ost_02 to the left without a left indicator |
| 2.7 s | unsafe_overtake | oncoming car car_004 had to brake at 2.6 m/s² 195 m ahead of the ego, which was passing cyclist_005 |
| 3.4 s | wrong_side | car centre on the left half of E_k7_ost_02 for 1.1 s with nothing being passed |
| 4.8 s | dithering | plan target speed oscillated by 9 km/h or more, two cycles in 4.7 s |
| 6.2 s | unsafe_overtake | oncoming car car_009 had to brake at 2.5 m/s² 172 m ahead of the ego, which was passing cyclist_005 |
| 6.9 s | missing_indicator | no right indicator for overtaking (back in) on E_k7_ost_02 |
| 9.8 s | dithering | plan target speed oscillated by 31 km/h or more, two cycles in 4.9 s |
| 12.2 s | dithering | plan target speed oscillated by 11 km/h or more, two cycles in 2.5 s |
| 50.3 s | dithering | behaviour flipped car_follow <-> stop 3 times in 6.8 s |
failed newest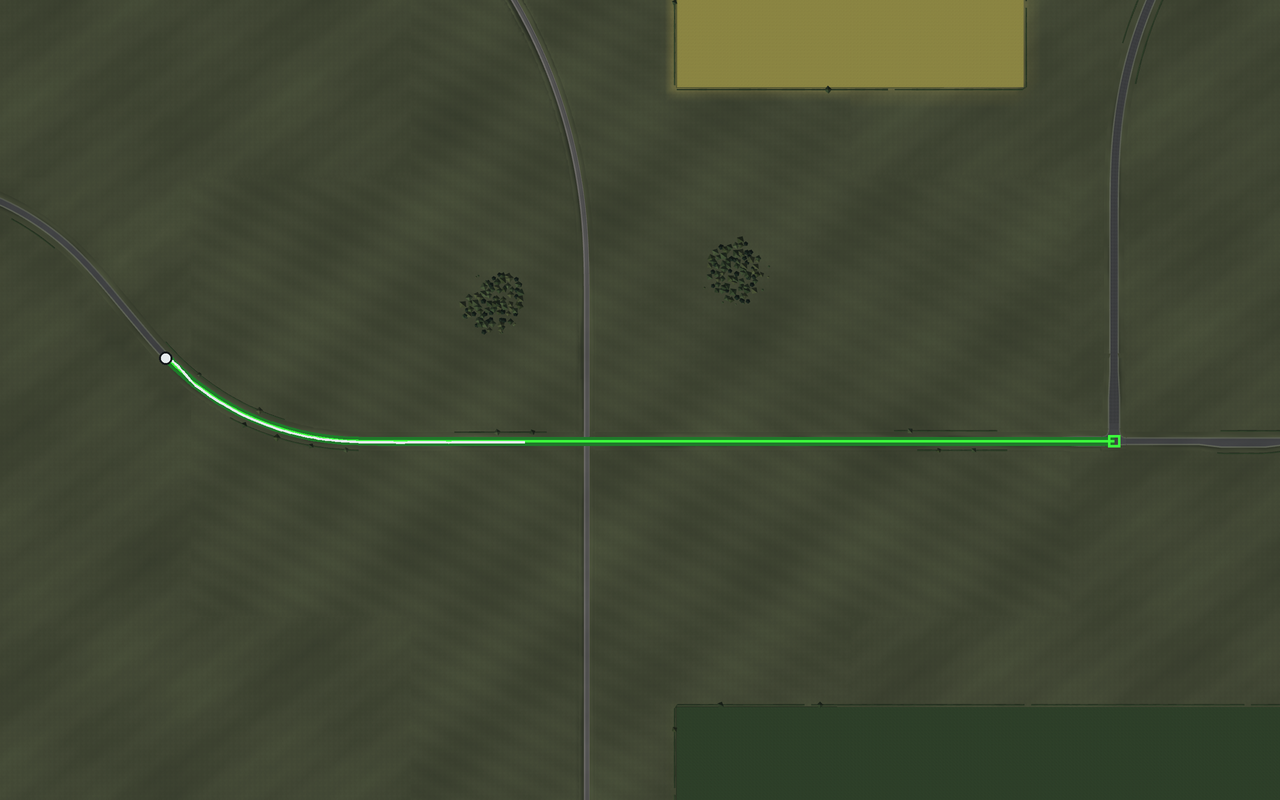
The user's words about the clip of 2026-10-04 session 4, written 2026-10-05“at the start of the clip it started driving on the wrong side of the road, at 0:38 it jerked to the side, following the cyclist was fine”
The lead's reading, not the user's and not the judge's
Pulls out to the left for a cyclist in the first seconds; three oncoming cars have to brake.
What changed since the version before: first version
route asked fordriven× collision or off the road
Run
- version
- 2026-10-04 session 4
- scenario
- level_crossing_k7
- ended
- time limit
- time
- 60.0 s
- distance
- 436 m
- mean speed
- 26.1 km/h
- stops
- 0
- code
- master c197752
- perception
- learned, front + tele
- seed
- 3